Engineering & manufacturing in Exeter, New Hampshire, USA since 1961 [email protected]
Toll Free (888) 597-9255 Tel +1 603-778-2300 Contact
0%

Selecting Robotic Power Components is no longer a minor purchasing task. It affects uptime, motion accuracy, heat, safety, and maintenance costs. The International Federation of Robotics reported 541,302 industrial robot installations worldwide in 2023, with more than 4.28 million robots operating globally. Every unit depends on reliable drives, controllers, connectors, batteries, sensors, and power supplies.

The market is expanding quickly. Grand View Research’s 2024 industrial robotics report projects continued growth through the decade, increasing pressure on manufacturers to improve efficiency and serviceability. A suitable component must match voltage, current, duty cycle, ambient temperature, ingress protection, and communication requirements. A connector that survives a clean factory may fail near oil mist, vibration, or repeated cable flexing. Small details matter.

Robotics researcher Rodney Brooks has said, “The robots are coming, but they are not going to take your jobs.” His observation highlights a practical point: robots support human work, but poor component choices create human troubleshooting. The seven tips ahead examine datasheet verification, thermal margins, power quality, compatibility, certification, supplier support, and lifecycle cost. No checklist is perfect. Real installations often expose assumptions that laboratory tests miss. Engineers should measure actual loads, inspect failure records, and question attractive specifications. A cheaper power module may look efficient on paper, yet generate costly downtime beside a hot motor cabinet. The right decision combines published evidence, field experience, and cautious judgment.
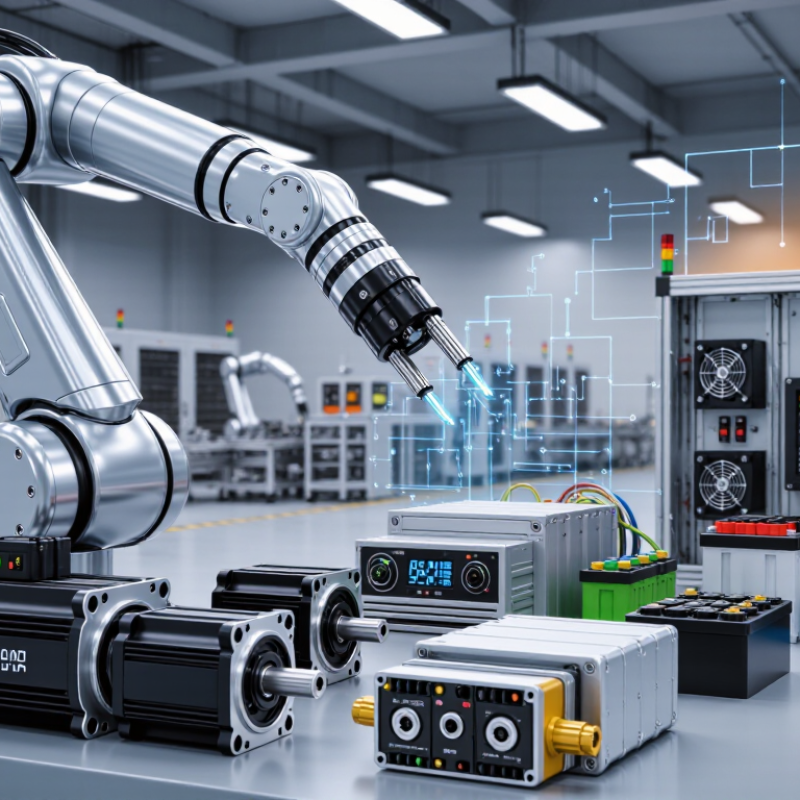
7 Tips for Choosing Robotic Power Components?

Define the Robot’s Power Requirements and Operating Conditions

A robot’s power system should begin with measured requirements, not a convenient component catalog. Record the voltage range, continuous current, and peak current for every actuator, sensor, controller, and communication module. A mobile robot may draw modest current while cruising, then demand three times more during acceleration or climbing.

Operating conditions change the calculation. Note the duty cycle, ambient temperature, dust, moisture, vibration, and available cooling. A joint moving every few seconds creates a different load from a conveyor arm running continuously. Battery voltage also falls during discharge, so components must operate safely at the lowest expected voltage. Leave practical headroom, but avoid excessive oversizing. It adds weight, cost, and sometimes slower response.

Use real measurements where possible. In power tests, I place a current probe near the battery and watch the voltage during sudden motor starts. Short peaks are easy to miss with basic meters. Protection needs equal attention: fuses, current limiting, thermal monitoring, reverse-polarity protection, and suitable connectors can prevent a small fault from spreading. Check datasheets carefully, especially temperature derating and transient ratings. A neat spreadsheet can still be wrong. Early estimates often ignore cable losses or simultaneous actuator movement. That mistake deserves a second test under the robot’s heaviest realistic workload. Load behavior may also change after software updates, so the power budget should remain a living document.

Compare Voltage, Current, Capacity, and Efficiency Specifications

Tip 1: Match voltage to the controller, motor, and sensors. A 24-volt system can fail when voltage dips during acceleration. Leave a practical margin, but avoid excessive voltage that stresses insulation and electronics.

Tip 2: Check continuous and peak current separately. A robot may draw modest current while moving, then surge during lifting or sudden direction changes. Tip 3: Measure real battery capacity in watt-hours, not amp-hours alone. Runtime depends on voltage, load, temperature, and discharge rate. The International Energy Agency reported global electric-vehicle battery demand above 750 GWh in 2023. That growth highlights the importance of accurate capacity and thermal planning. Tip 4: Derate capacity in cold environments. Published figures often assume ideal laboratory conditions. Real floors are less forgiving.

Tip 5: Compare efficiency across the complete power path. Include the battery, converter, wiring, motor driver, and motor. A component rated at 95% efficiency still wastes noticeable energy under continuous high load. Tip 6: Inspect heat dissipation closely. Measure case temperature after repeated cycles, not after one easy movement. I once trusted a nominal efficiency figure and underestimated enclosure heating. That mistake was avoidable. Tip 7: Verify transient response and protection features. The IEC 60204-1 machinery-safety framework emphasizes reliable electrical protection and controlled equipment behavior. Request test conditions, current curves, and endurance results. If a specification lacks those details, treat it as incomplete.

7 Tips for Choosing Robotic Power Components? - Compare Voltage, Current, Capacity, and Efficiency Specifications

Typical specification ranges for common robotic power-system components

Tip Component or Selection Focus Nominal Voltage Continuous Current Peak Current Capacity or Power Typical Efficiency Practical Selection Check
1 Match the battery voltage to the system bus 12–48 VDC 10–100 A 20–200 A 120–4,800 Wh 90–97% Select a battery whose operating voltage remains within the input range of the motor controllers, sensors, and converters.
2 Size continuous and peak current correctly 24–48 VDC 15–80 A 30–160 A 0.4–3.8 kW 93–98% Use continuous current for sustained motion and peak current for acceleration, lifting, starting, or stall events.
3 Calculate battery capacity from runtime 22.2–51.8 VDC 5–60 A 10–120 A 10–100 Ah 85–95% usable Estimate energy using Wh = V × Ah, then include a reserve of about 15–25% for temperature, aging, and high-load operation.
4 Choose an efficient DC-DC converter 18–60 V input 5–30 A output Up to 45 A 60–720 W 90–96% Verify output voltage, ripple, thermal derating, isolation requirements, and enough power for the peak sensor or computer load.
5 Check motor-controller power headroom 24–72 VDC 10–100 A 20–200 A 0.25–7.2 kW 95–99% Allow approximately 20% current margin above the calculated continuous motor demand and confirm short-duration peak ratings.
6 Evaluate thermal performance and efficiency 12–60 VDC 10–80 A 20–160 A 0.2–4.8 kW 88–97% Lower losses reduce heat. Check cooling airflow, enclosure rating, ambient temperature, and derating curves rather than relying only on peak efficiency.
7 Use protection, monitoring, and regenerative-energy control 12–60 VDC 20–100 A 40–200 A 0.3–6.0 kW 90–98% Include overcurrent, overvoltage, undervoltage, short-circuit, and temperature protection; verify that braking energy will not exceed the battery or bus limits.
Note: Values are representative engineering ranges for preliminary comparison. Final component selection should use the applicable datasheet, duty cycle, ambient temperature, safety requirements, and transient-load measurements.

Select Suitable Batteries, Power Supplies, and Distribution Components

7 Tips for Choosing Robotic Power Components?

Selecting robotic power components requires more than matching voltage labels. Start with the battery’s nominal voltage, peak current, capacity, cycle life, and discharge temperature range. A battery rated for 20 amps may fail during motor acceleration. Check the real load profile, including startup surges and emergency stops. The IEA reported that lithium-ion battery pack prices fell 14% in 2023, but lower prices do not guarantee better suitability.

Choose a power supply with continuous headroom, not only the robot’s average demand. A practical target is 20% to 30% spare capacity, especially for systems with several actuators. Verify efficiency, thermal performance, short-circuit protection, and transient response. Keep cables short and properly sized. Excessive voltage drop can cause unstable sensors or controller resets. It happens more often than expected. The International Federation of Robotics reported 541,302 industrial robot installations in 2023, showing why dependable power design matters across demanding production environments.

Distribution components deserve equal attention. Select fuses, circuit breakers, terminal blocks, connectors, and busbars according to current, fault levels, vibration, and enclosure conditions. Separate sensitive control circuits from high-current motor paths when possible. Add monitoring for voltage, temperature, and battery state. These measurements can reveal a loose connection before failure becomes expensive. IEC 60204-1 provides widely used guidance for electrical equipment in machinery, but site conditions still require engineering judgment. I would not treat any checklist as perfect; testing under actual payloads remains essential.

7 Tips for Choosing Robotic Power Components

Select batteries, power supplies, and distribution components by comparing efficiency, voltage compatibility, peak-load capability, thermal performance, protection, service life, and safety requirements.

The chart shows representative engineering efficiency ranges commonly used during early robotic power-system sizing. Actual performance depends on load current, temperature, wiring length, switching frequency, battery condition, and safety margins.

  • Define the load: Calculate continuous, startup, stall, and peak power requirements.
  • Match voltage: Keep battery, power supply, motor drivers, sensors, and controllers within their specified voltage ranges.
  • Size for peaks: Choose batteries and converters that can handle short-duration surge current without excessive voltage sag.
  • Check efficiency: Higher efficiency reduces heat, cooling requirements, and battery energy loss.
  • Plan protection: Use appropriately rated fuses, breakers, current limiting, reverse-polarity protection, and emergency disconnects.
  • Control heat: Consider enclosure temperature, airflow, duty cycle, connector ratings, and cable losses.
  • Allow headroom: Reserve capacity for aging, expansion, cold temperatures, and temporary overloads.

Evaluate Safety Features, Environmental Ratings, and Reliability

Choosing robotic power components requires more than checking voltage and current. The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023. That scale makes component reliability a production concern, not a minor specification. Start by matching rated load with real peak demand. Check inrush current, heat rise, short-circuit protection, and connector locking strength. A component that survives the laboratory may still fail beside a hot servo motor.

Safety features deserve direct verification. Look for overcurrent, overvoltage, thermal, and isolation protection. For safety-related functions, review evidence against IEC 61508 or ISO 13849 requirements. Do not accept a generic “safe design” statement. Ask for test conditions, fault responses, and diagnostic coverage. Small details matter, such as whether a failed fan creates a controlled shutdown. Sometimes, it does not. That risk needs honest review.

Environmental ratings should match the installation, not the brochure photograph. IEC 60529 IP ratings address dust and water ingress, but they do not fully describe vibration, oil mist, corrosion, or repeated thermal cycling. Select components with suitable temperature ranges and derating curves. Then examine MTBF data, service history, warranty conditions, and replacement lead times. The IFR’s World Robotics 2024 report recorded 4.28 million industrial robots operating globally in 2023, highlighting the cost of avoidable downtime. Still, MTBF is only a statistical estimate. It cannot predict every cable bend, loose terminal, or maintenance mistake. Field inspection remains necessary.

Check Compatibility, Maintenance Needs, and Future Scalability

7 Tips for Choosing Robotic Power Components?

Reliable robotic power design starts with compatibility, not price. Confirm voltage range, peak current, connector type, mounting space, and communication requirements. Check the datasheet against real operating conditions. A controller that survives steady loads may fail during motor startup. Measure those surges with a suitable meter.

Maintenance needs deserve equal attention. Choose components with accessible terminals, clear status indicators, and replaceable protection parts. Inspect cooling paths, cable bends, and battery connections during scheduled service. Dust near a fan can quietly raise temperatures. Keep spare fuses and documented wiring diagrams nearby. Small details matter.

Think beyond today’s prototype. Leave space for higher current cables, extra sensors, and a larger power supply. Select components with useful diagnostic data and adjustable protection settings. Confirm their thermal performance at the robot’s maximum duty cycle. Standard interfaces can simplify future upgrades. They can also create unexpected compatibility issues. I have seen a clean installation become difficult after one connector change. Review the expansion plan before purchasing.

Ask suppliers for test records, operating limits, and warranty conditions. Compare independent measurements when possible. A polished specification sheet is not proof of field reliability. Run a short pilot under vibration, heat, and repeated start-stop cycles. Record failures honestly. That imperfect data often reveals the safest component choice.

FAQS

How should I choose a battery for a robotic system?

Check nominal voltage, peak current, capacity, cycle life, and discharge temperature. A battery rated for 20 amps may fail during motor acceleration. Measure startup surges and emergency-stop loads. Surges matter.

How much spare capacity should a power supply have?

Keep about 20% to 30% spare capacity above continuous demand. This margin helps systems with several actuators and changing loads. Check efficiency, heat rise, short-circuit protection, and transient response. Average demand alone is not enough.

Why do cable size and length matter?

Long or undersized cables can create voltage drop. Sensors may become unstable, and controllers may reset unexpectedly. Use short, properly sized cables where possible. Measure voltage at the load, not only at the supply.

Which distribution components need careful selection?

Select fuses, breakers, terminals, connectors, and busbars for actual current and fault levels. Consider vibration, enclosure temperature, dust, and connection security. Separate sensitive control wiring from high-current motor paths when practical. A loose terminal can become expensive.

What safety features should robotic power components include?

Verify overcurrent, overvoltage, thermal, and isolation protection. Ask for test conditions, fault responses, and diagnostic coverage. Do not rely on a general “safe design” statement. A failed fan should create a controlled shutdown, but it may not.

How should environmental conditions affect component selection?

Match temperature, dust, moisture, vibration, oil mist, and corrosion resistance to the installation. Ingress protection ratings do not describe every operating condition. Review derating curves and thermal performance near hot motors. A clean workshop test is not enough.

What maintenance details should be checked before purchasing?

Choose accessible terminals, clear indicators, and replaceable protection parts. Inspect cooling paths, cable bends, and battery connections during scheduled service. Keep spare fuses and updated wiring diagrams nearby. Dust near a fan can quietly raise temperatures.

How can I prepare the power system for future expansion?

Leave room for larger cables, extra sensors, and a higher-capacity power supply. Choose useful diagnostic data and adjustable protection settings. Confirm connector, mounting, and communication compatibility before upgrading. One connector change can complicate a clean installation.

How should components be tested before full deployment?

Run a pilot under maximum payload, vibration, heat, and repeated start-stop cycles. Record voltage, temperature, battery condition, and unexpected resets. Compare supplier records with independent measurements when possible. The checklist will not be perfect. Real testing exposes weak assumptions.

Conclusion

Choosing the right Robotic Power Components is essential for building a safe, efficient, and dependable robotic system. Start by defining the robot’s power requirements, including operating voltage, current demand, peak loads, runtime, movement patterns, and working environment. Compare battery and power supply specifications carefully, considering capacity, energy efficiency, charging needs, and power losses. Select batteries, power supplies, regulators, connectors, and distribution components that can support both normal operation and temporary surges without excessive heat or performance drops.

Safety and long-term reliability should also guide every decision. Look for protection against overcurrent, overheating, short circuits, and unstable voltage, while confirming that components suit the robot’s temperature, moisture, dust, and vibration conditions. Check electrical and mechanical compatibility, installation requirements, maintenance frequency, and replacement availability. Finally, consider future scalability so the power system can support additional sensors, actuators, or control equipment without requiring a complete redesign. A thoughtful selection process improves performance, simplifies maintenance, and extends the robot’s service life.
Seraphina

Seraphina

Seraphina is a dedicated marketing professional with a strong understanding of product strategy, customer needs, and market trends. As a key contributor to the company’s communications team, she regularly updates the corporate website with insightful, practical blog articles that help readers......